Introduction
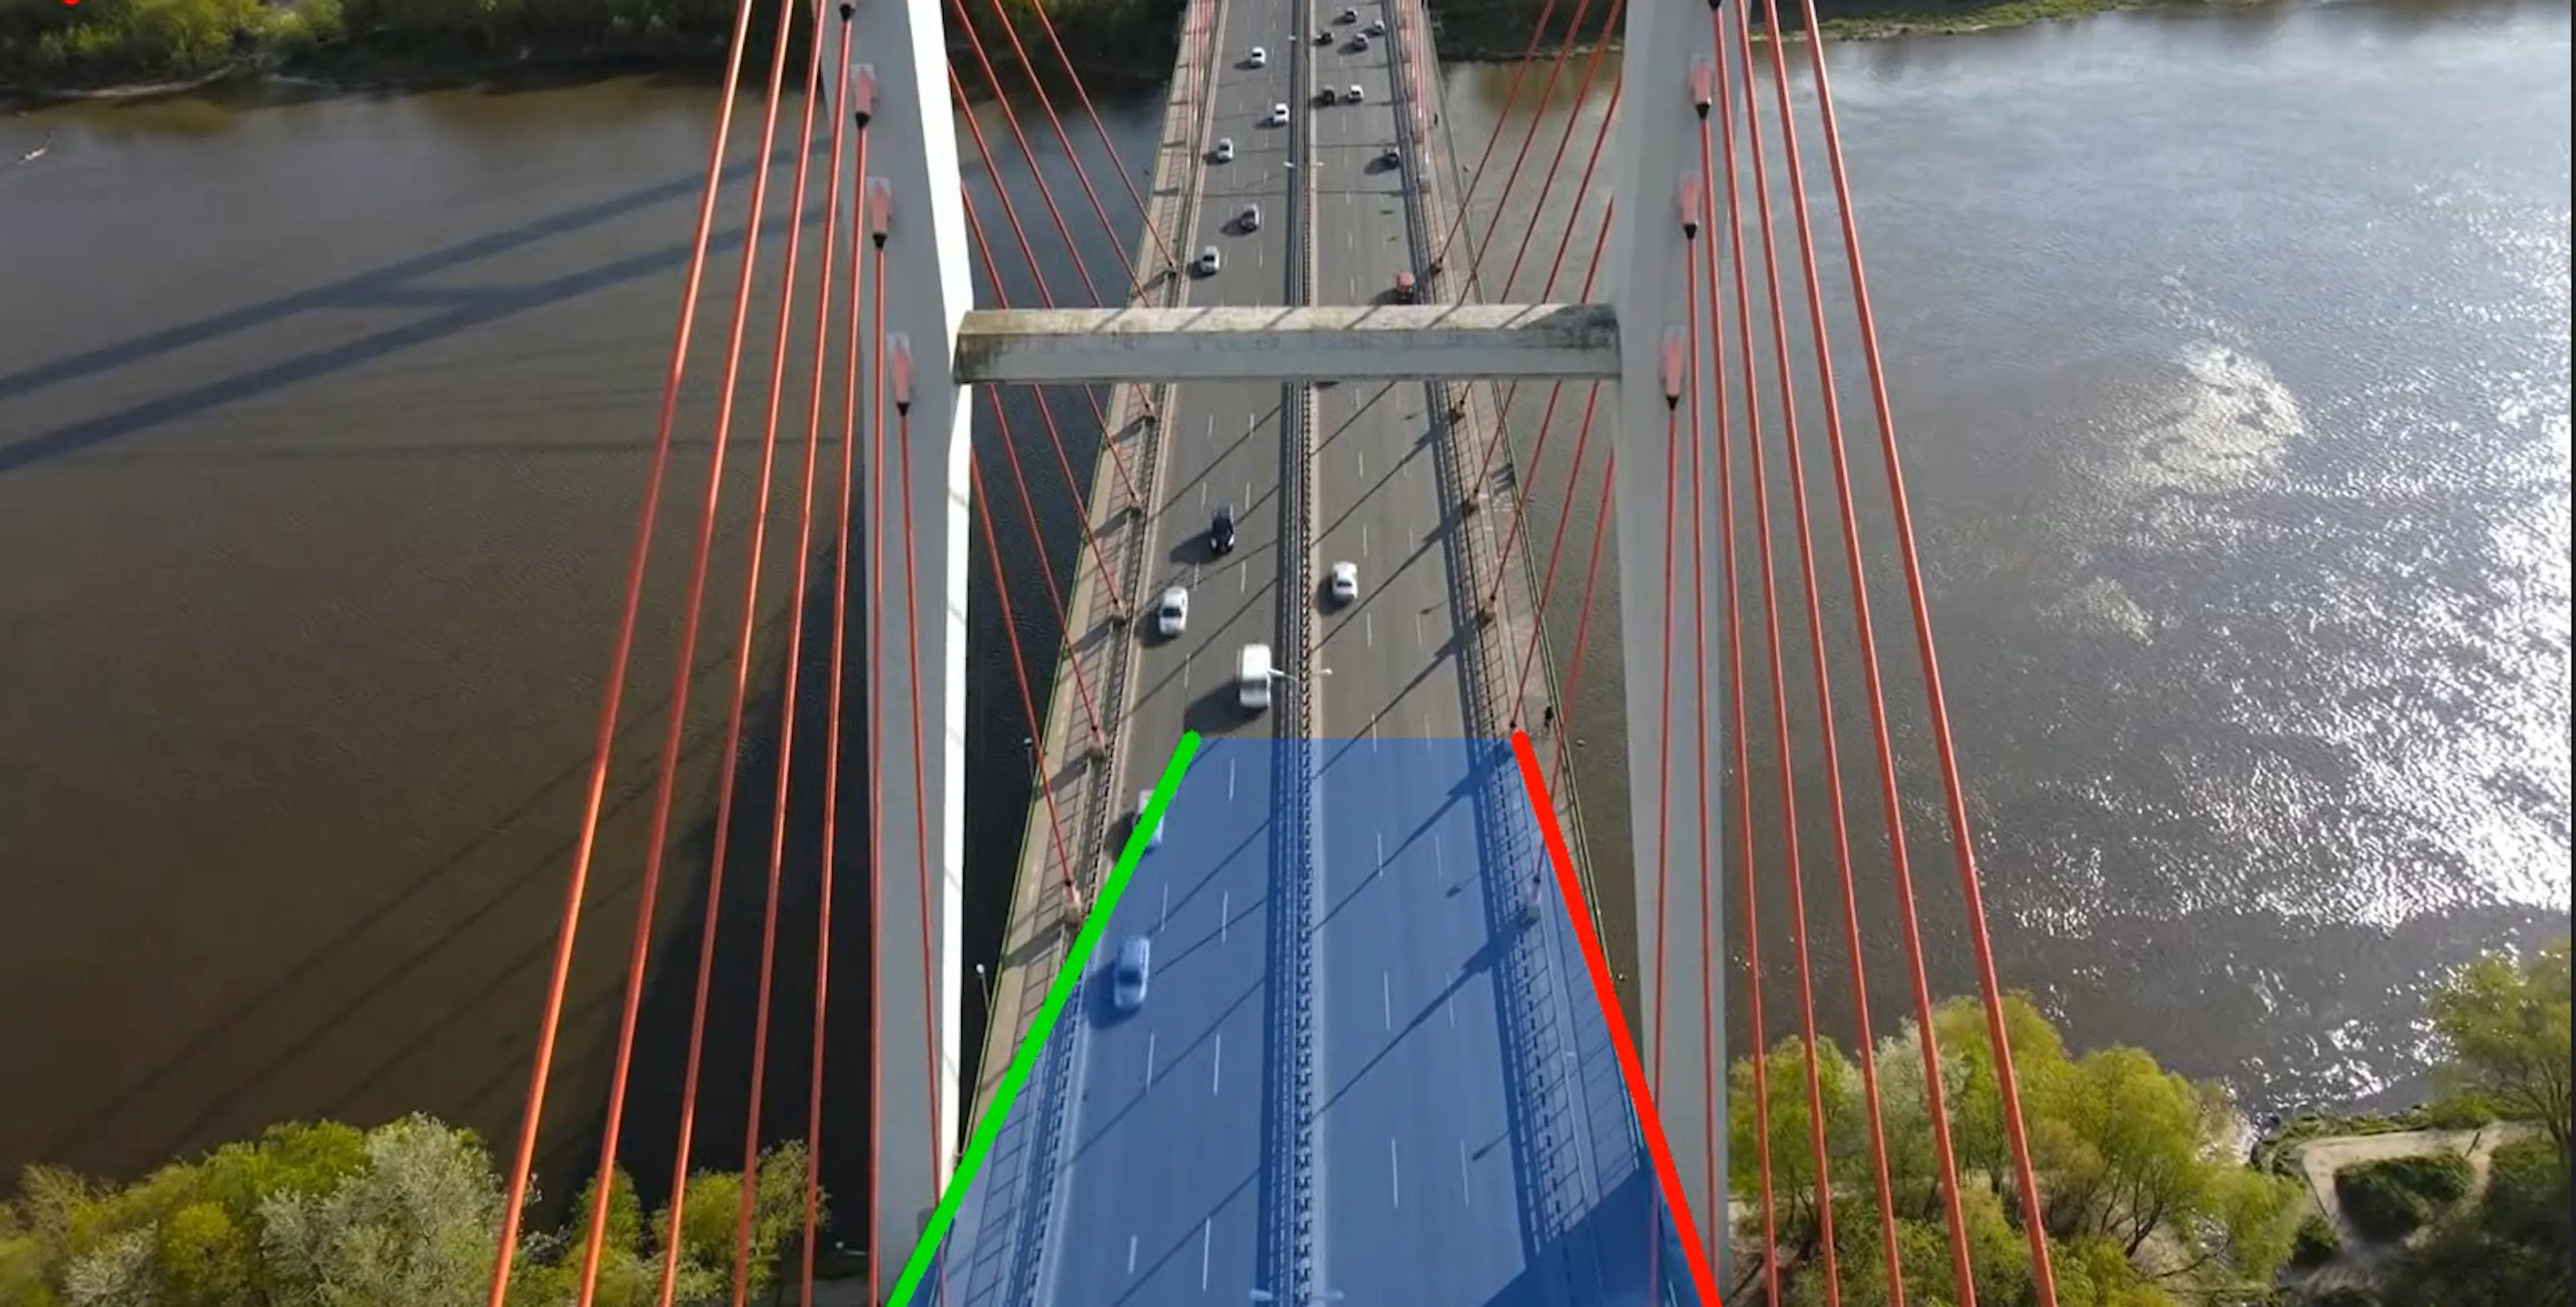
The rapid evolution of autonomous flight has positioned drones as more than remote-controlled cameras. Today, AI-driven systems enable UAVs to perceive, reason, and navigate complex environments without constant human input. This post examines how AI agents are integrated into drone architecture, the classical stacks that still govern safe flight, and the practical realities that determine success in the field.
What Happened
The path to autonomous drone navigation unfolded across four distinct eras. Manual control dominated early operations, restricting flights to line-of-sight under direct pilot input. GPS-assisted waypoint navigation expanded range but failed without satellite signals. Sensor-fusion systems combined inertial measurement units, cameras, and lidar to maintain situational awareness even when GPS was unavailable. The current frontier, AI-driven autonomy, leverages machine learning to adapt flight behavior in real time, handling unpredictable obstacles and dynamic environments that classical planners cannot anticipate.
Why This Matters
Autonomous drones are transitioning from experimental platforms to operational tools across delivery, agriculture, surveillance, and emergency response. The ability to fly GPS-denied, follow natural-language commands, and dynamically avoid obstacles expands the types of missions a UAV can undertake. Furthermore, foundation-model-driven agents are shifting the paradigm from rigid trajectory following to task-level reasoning, allowing drones to interpret high-level instructions and adjust their behavior accordingly.
Key Takeaways
- Classical autonomy relies on four interconnected layers: perception, processing, control, and communication. Each layer must function reliably for safe flight, especially in challenging environments.
- AI agents, particularly vision-language and vision-language-action models, introduce natural-language command following and high-level mission reasoning.
- Onboard compute and power budgets remain the primary constraint for deploying large neural networks on small airframes. Efficient edge hardware and model compression are active research areas.
- Development workflows prioritize simulation before flight. Physics-based simulators, hardware-in-the-loop testing, and staged real-world trials from tethered to outdoor operations reduce risk and validate performance.
- Operational success depends on more than algorithmic accuracy. Airspace compliance, cybersecurity safeguards, and mission-level metrics such as task completion rate and failure-mode analysis are essential for deployable systems.
Conclusion
The field has reached an inflection point where better sensors, more capable models, and mature control frameworks coexist, enabling drones to operate across diverse commercial and public safety scenarios. However, the remaining hurdles reliable onboard inference safety certification for learned policies and seamless airspace integration are engineering challenges rather than purely algorithmic ones. A layered approach combining classical reliability with foundation-model reasoning and a commitment to rigorous testing from simulation through live deployment will determine which AI-agent drones transition from research demos to mission-critical tools.

Discussion
Join the conversation
Thoughtful reactions, questions, and follow-up ideas help shape the next story.